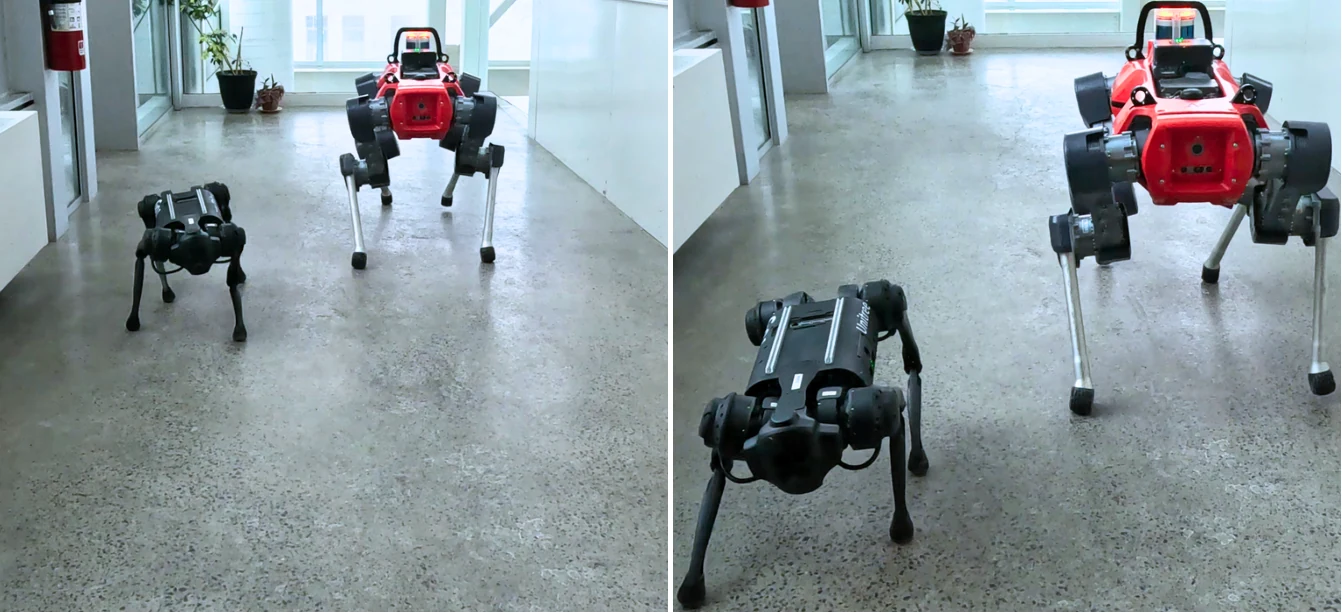
Morphology-Conditioned World Model for Cross-Embodiment Quadrupedal Locomotion
QWM conditions a single generative dynamics model on scale-invariant morphology features and trains locomotion policies entirely in imagination. Given the same morphology information, a model-free policy degrades on unseen robots while QWM transfers zero-shot; to our knowledge, it is the first world model to show zero-shot cross-embodiment transfer within the quadrupedal family.