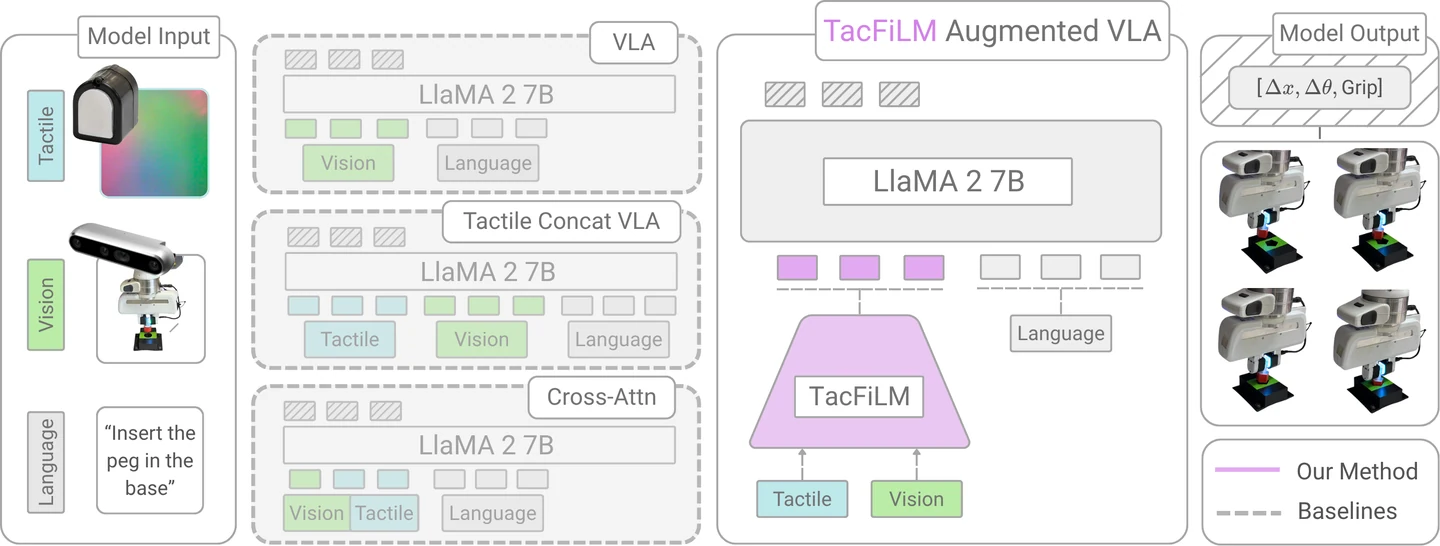
TacFiLM overview: tactile, visual, and language inputs, baseline fusion approaches, and the TacFiLM-augmented VLA.

Tactile Modality Fusion for Vision-Language-Action Models

TacFiLM is a lightweight post-training fusion method that conditions a VLA’s intermediate visual features on pretrained tactile representations through feature-wise linear modulation, improving success rate, completion time, and force stability on contact-rich insertion and drawer-opening tasks.
March 2026 · Anas Houssaini
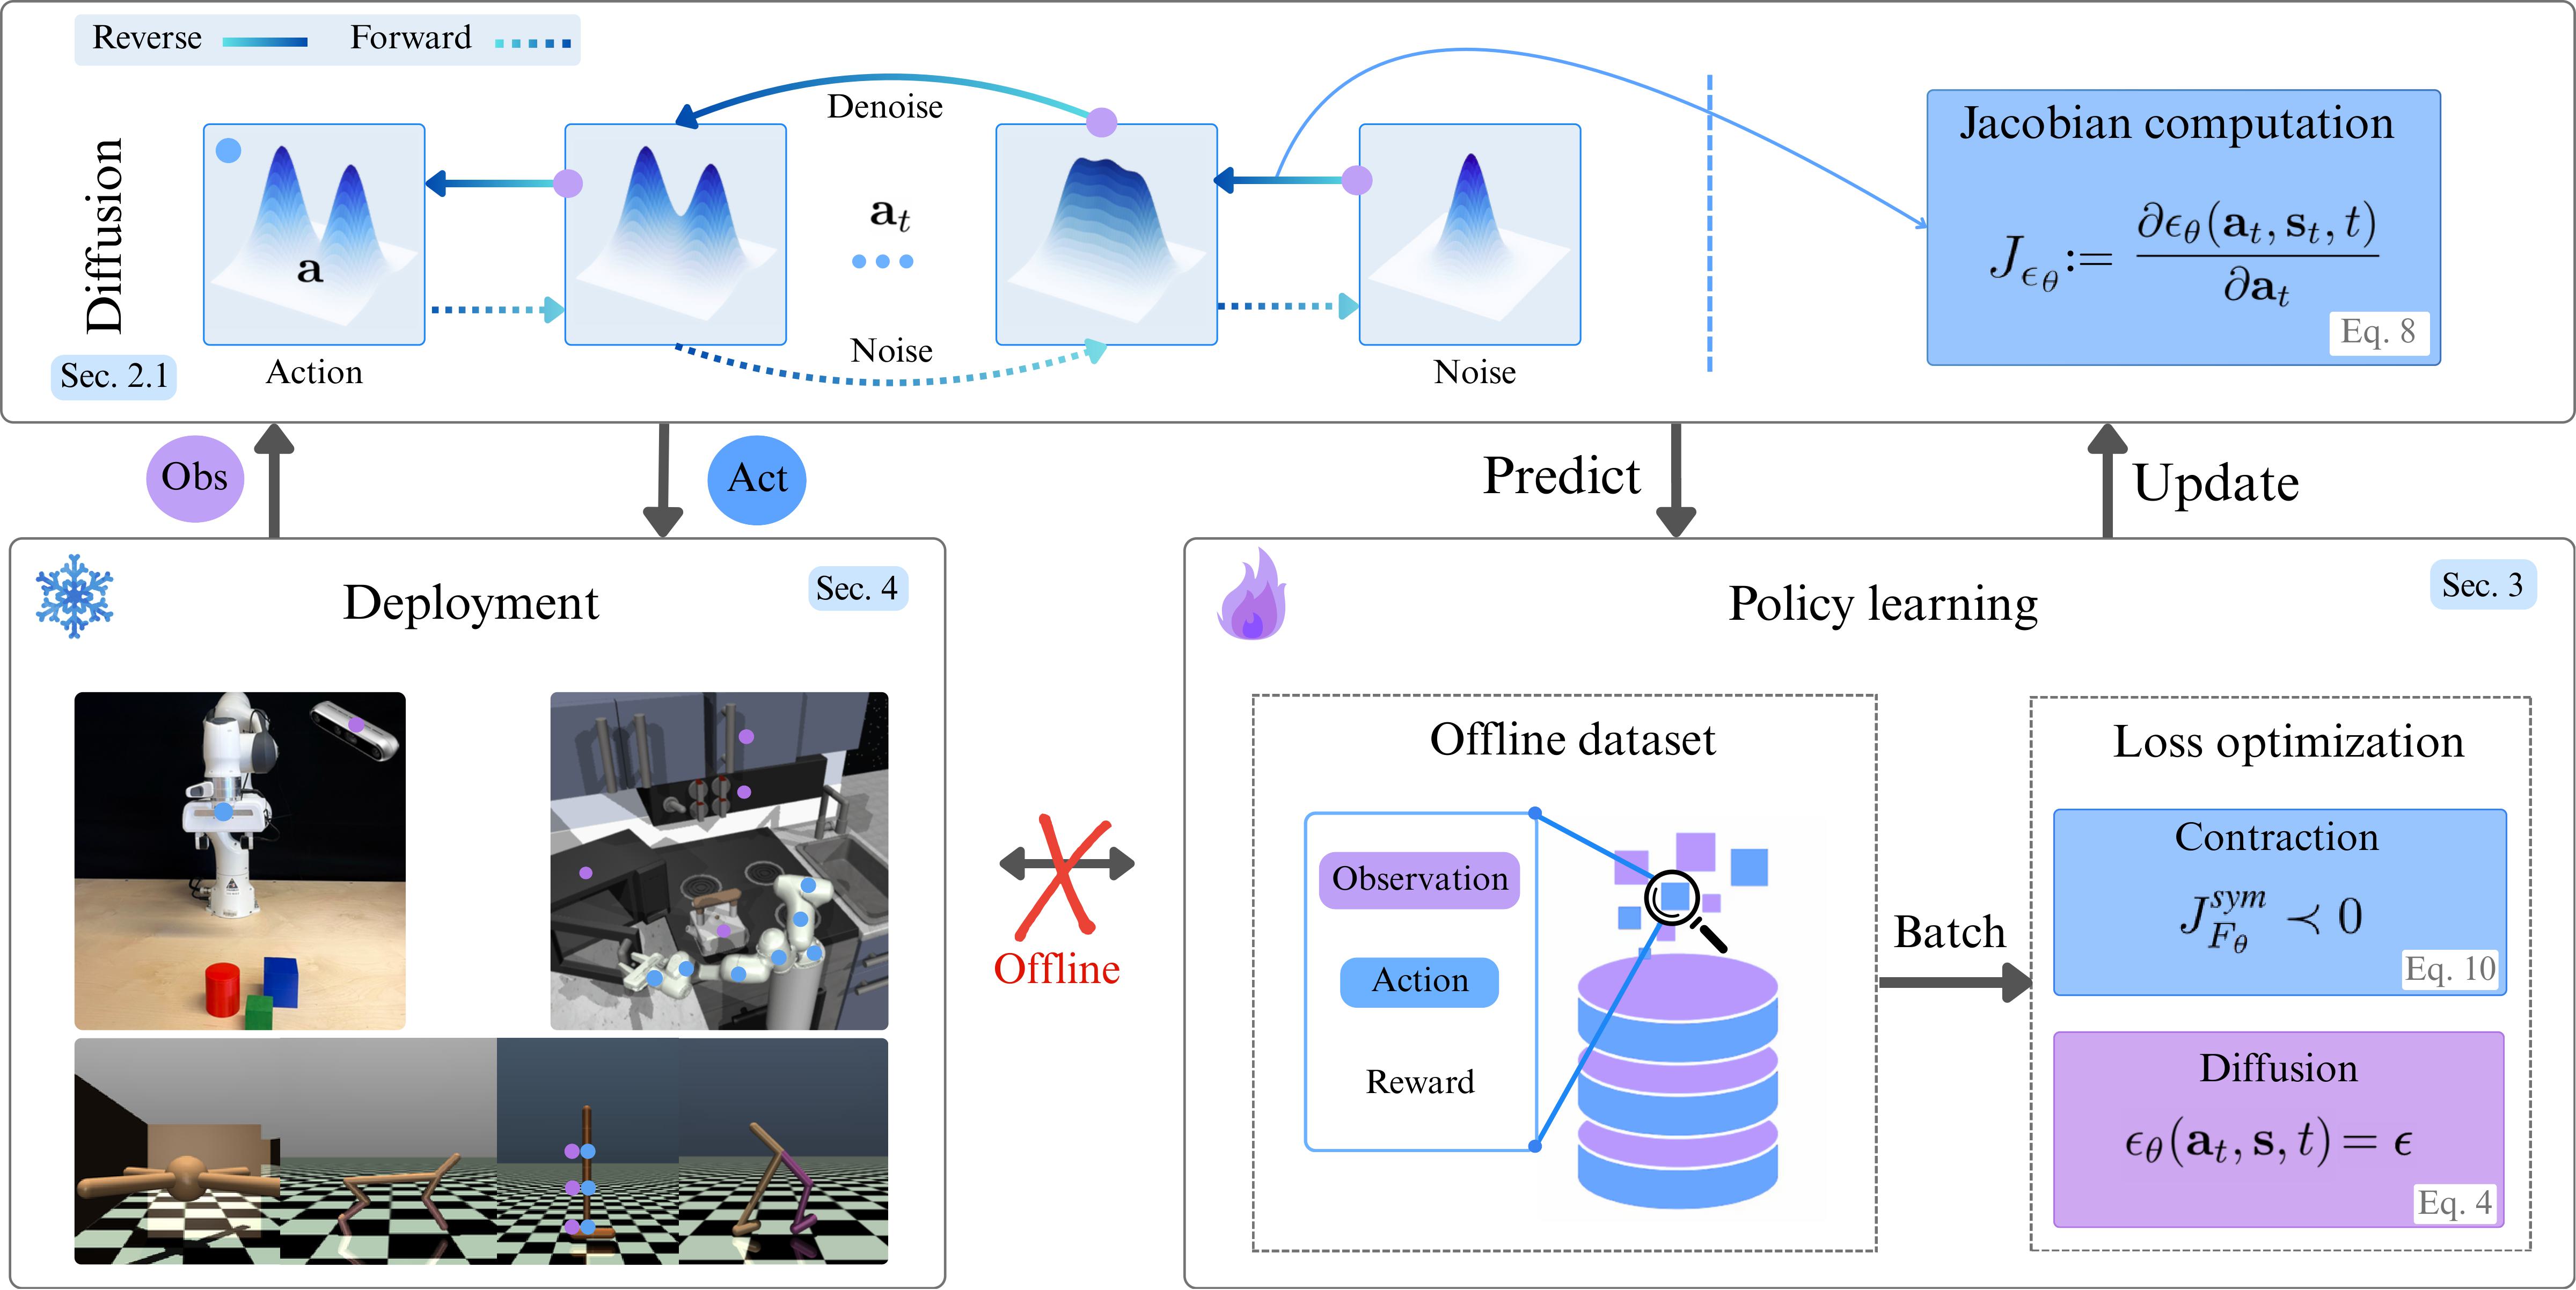
Methodology overview of Contractive Diffusion Policies.

Contractive Diffusion Policies: Robust Action Diffusion via Contractive Score-Based Sampling with Differential Equations

CDPs add a contraction regularizer to diffusion policies that pulls nearby sampling flows together, suppressing solver and score-matching errors and unwanted action variance. Backed by theory and a practical recipe with a single extra hyperparameter, they often outperform standard diffusion policies in simulation and on real robots, most clearly when data is scarce.

January 2026 · Anas Houssaini
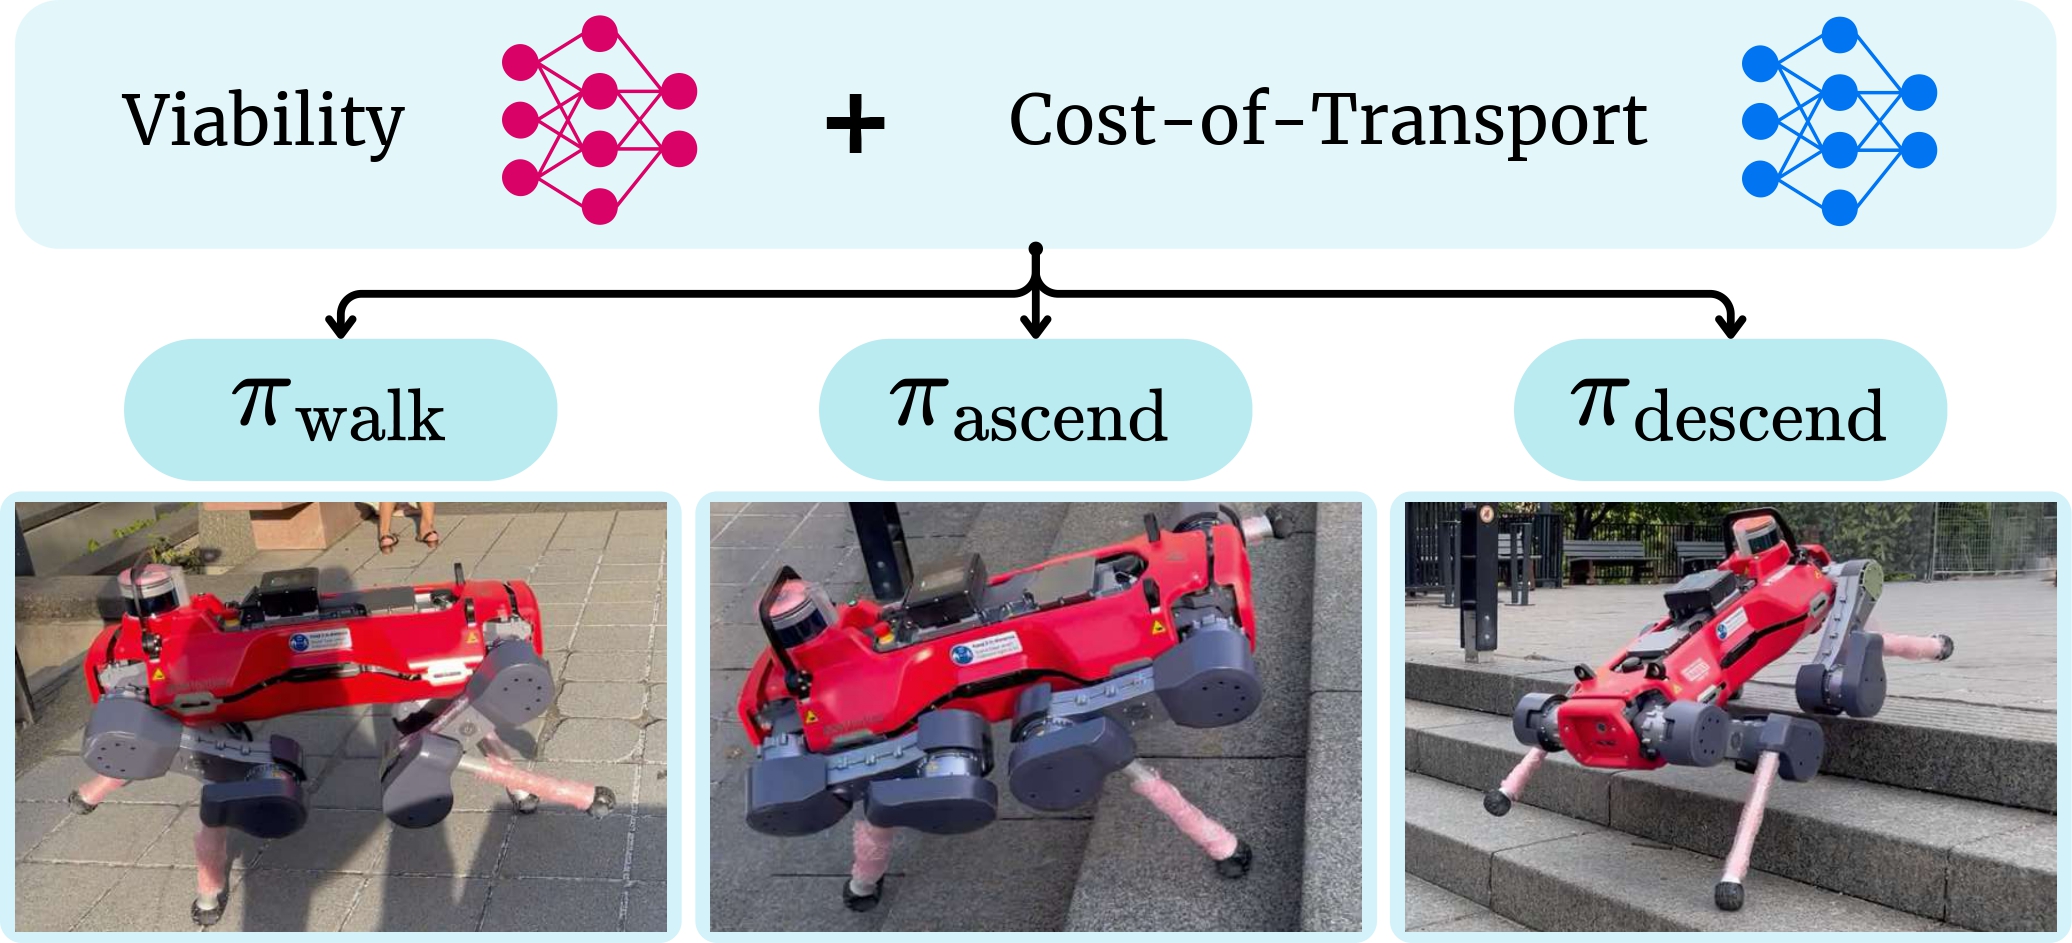
Overview of the VOCALoco framework showing skill viability prediction and selection.

VOCALoco: Viability-Optimized Cost-aware Adaptive Locomotion

VOCALoco predicts the viability and cost of transport of several pretrained locomotion skills from local heightmaps, then executes the safest, most efficient one. It improves robustness on stair ascent and descent over an end-to-end DRL policy and transfers to a real ANYmal-D quadruped.

October 2025 · Anas Houssaini