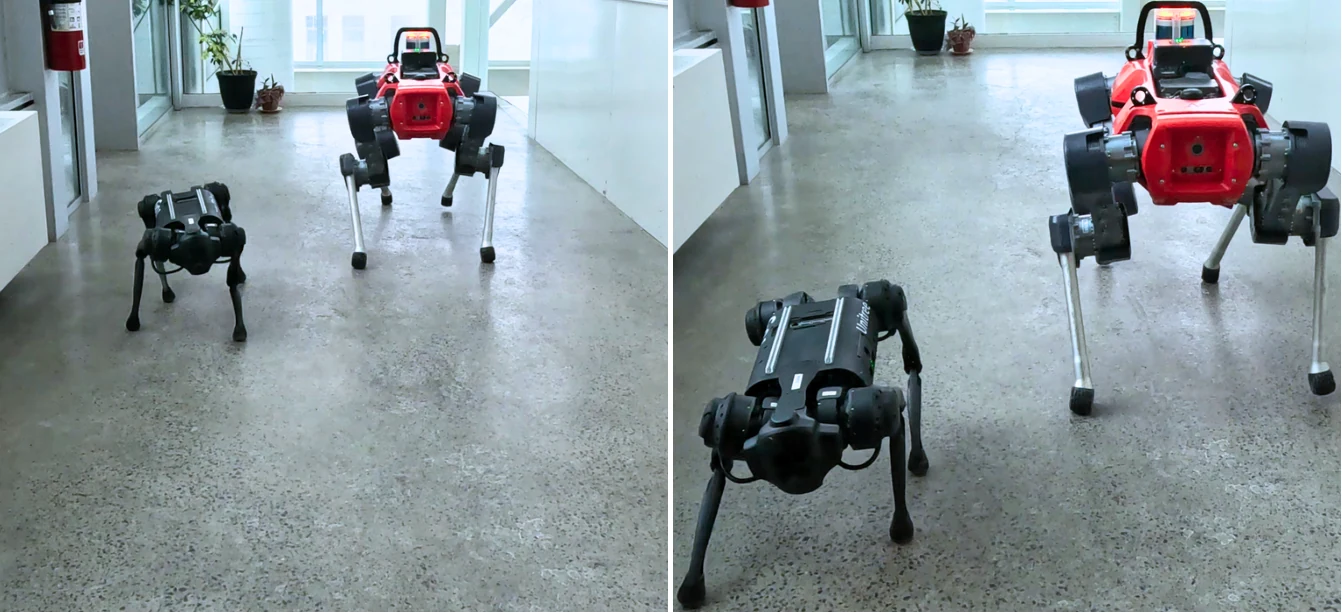
Locomotion policies trained inside the Quadrupedal World Model deployed on real quadrupedal robots.

Morphology-Conditioned World Model for Cross-Embodiment Quadrupedal Locomotion

QWM conditions a single generative dynamics model on scale-invariant morphology features and trains locomotion policies entirely in imagination. Given the same morphology information, a model-free policy degrades on unseen robots while QWM transfers zero-shot; to our knowledge, it is the first world model to show zero-shot cross-embodiment transfer within the quadrupedal family.
April 2026 · Anas Houssaini
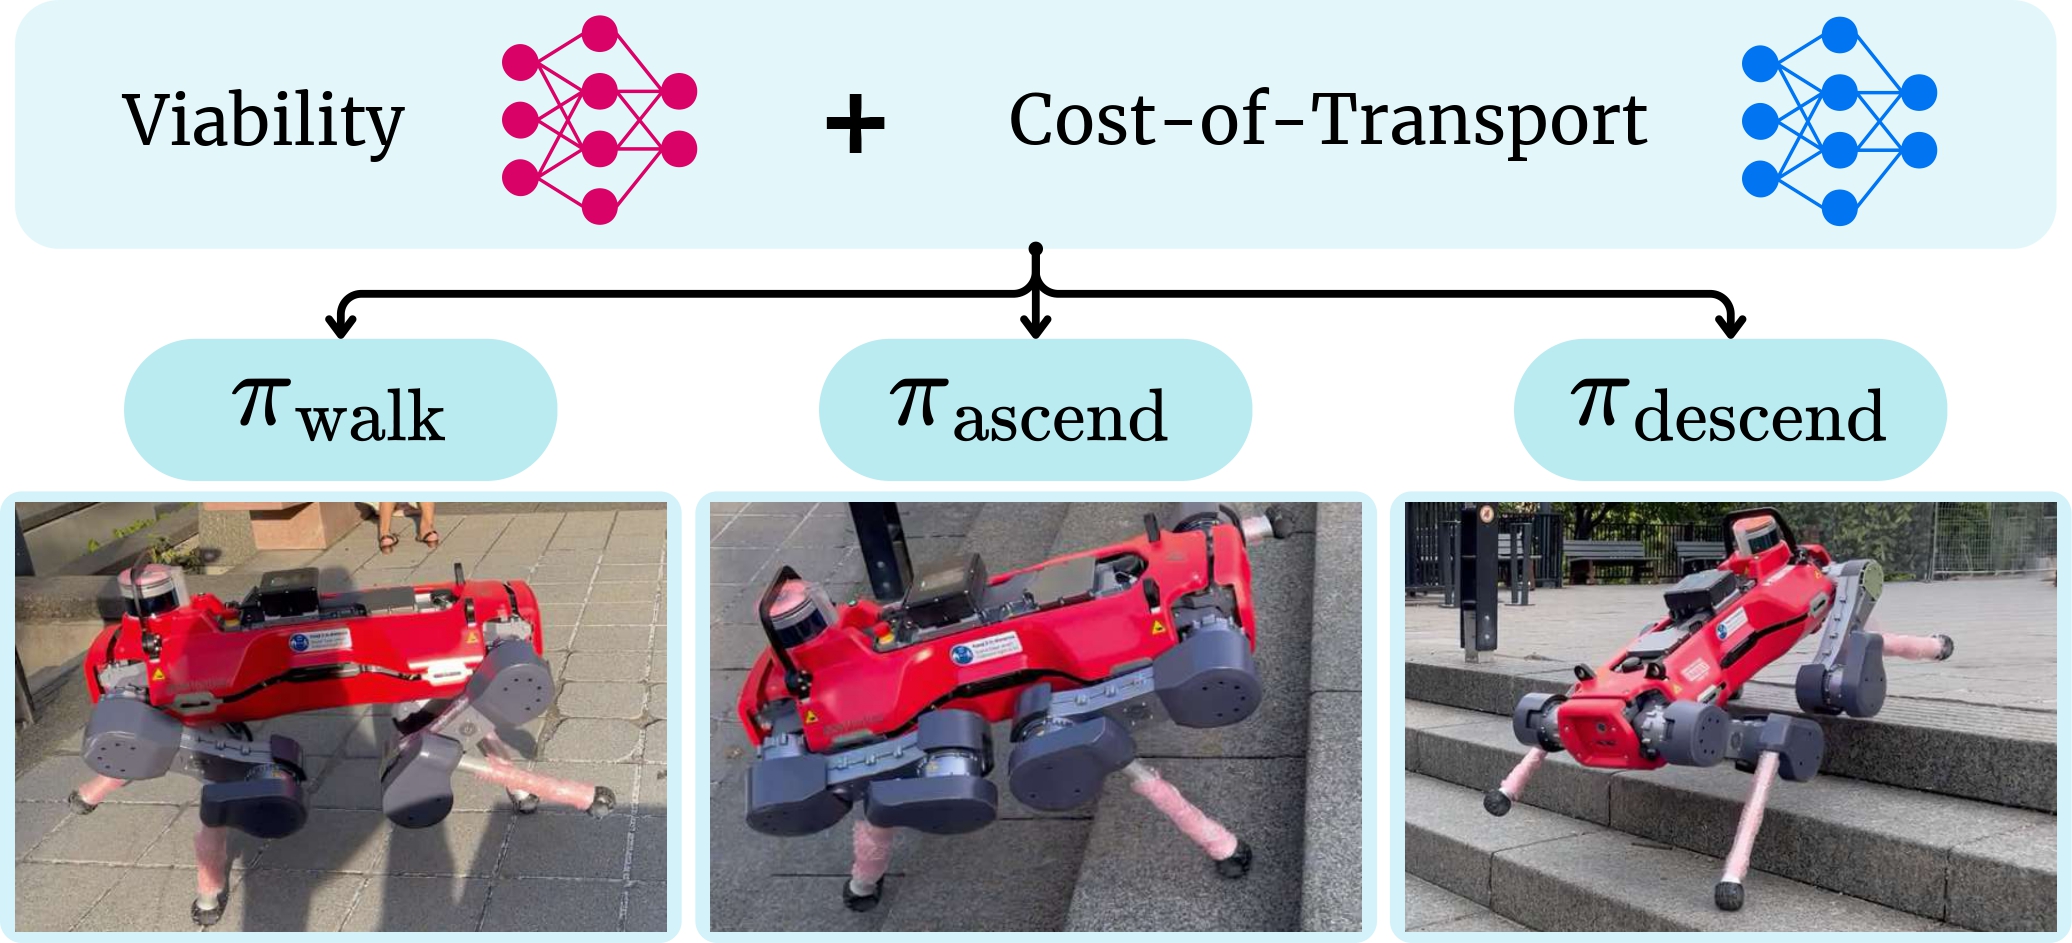
Overview of the VOCALoco framework showing skill viability prediction and selection.

VOCALoco: Viability-Optimized Cost-aware Adaptive Locomotion

VOCALoco predicts the viability and cost of transport of several pretrained locomotion skills from local heightmaps, then executes the safest, most efficient one. It improves robustness on stair ascent and descent over an end-to-end DRL policy and transfers to a real ANYmal-D quadruped.

October 2025 · Anas Houssaini