2026

NeurIPS 2026

Drift Q-Learning

Anas Houssaini*, Mohamad H. Danesh*, Amin Abyaneh, Scott Fujimoto, Hsiu-Chin Lin, David Meger

DriftQL is a one-step offline RL policy that replaces diffusion and flow denoising with a learned drift field: attraction keeps actions on the data, repulsion keeps them diverse, and the critic tilts them toward high value. State of the art on D4RL and OGBench, and robust to noisy datasets.

DexSuite: A Unified Simulation Framework for Dexterous Manipulation

Anas Houssaini, Hugo He, Junming Shi, Amin Abyaneh, Ricardo Chahine, Shuo Wen, Mohamad H. Danesh, Theophile Soulie, Mariana Sosa Guzmán, Mathias Desrochers, Rayan Houssaini, Marcus Kam, Charlotte Morissette, Martino Russi, Jonathan Lussier, Gregory Dudek, Doina Precup, Hsiu-Chin Lin, David Meger

DexSuite is a modular simulation framework and benchmark for multi-fingered hands, standardizing observations, actions, and evaluation across 20+ arm–hand configurations, single-arm and bimanual tasks, and rigid, articulated, and deformable objects. It ships with a Manus-glove teleoperation toolchain and an expert demonstration dataset.
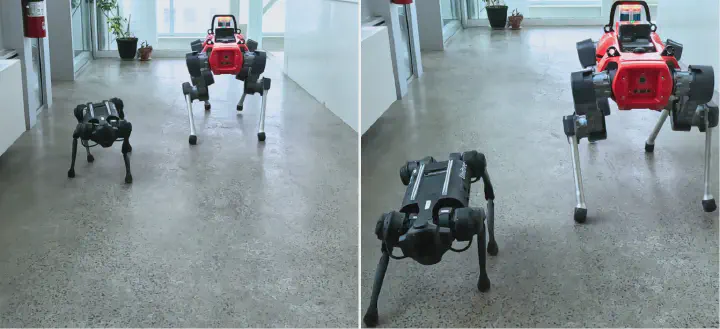
Locomotion policies trained inside the Quadrupedal World Model deployed on real quadrupedal robots.

CoRL 2026

Morphology-Conditioned World Model for Cross-Embodiment Quadrupedal Locomotion

Mohamad H. Danesh, Chenhao Li, Amin Abyaneh, Anas Houssaini, Kirsty Ellis, Glen Berseth, Marco Hutter, Hsiu-Chin Lin

QWM conditions a single generative dynamics model on scale-invariant morphology features and trains locomotion policies entirely in imagination. Given the same morphology information, a model-free policy degrades on unseen robots while QWM transfers zero-shot; to our knowledge, it is the first world model to show zero-shot cross-embodiment transfer within the quadrupedal family.

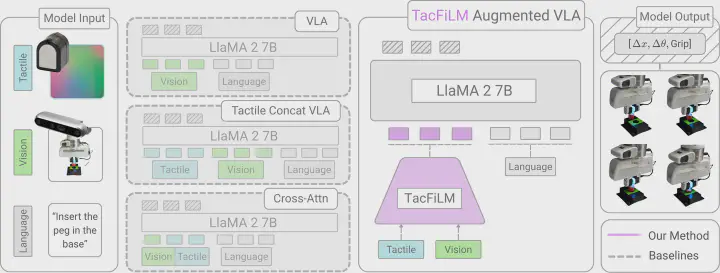
TacFiLM overview: tactile, visual, and language inputs, baseline fusion approaches, and the TacFiLM-augmented VLA.

ECCV 2026

Tactile Modality Fusion for Vision-Language-Action Models

Charlotte Morissette, Amin Abyaneh, Wei-Di Chang, Anas Houssaini, David Meger, Hsiu-Chin Lin, Jonathan Tremblay, Gregory Dudek

TacFiLM is a lightweight post-training fusion method that conditions a VLA’s intermediate visual features on pretrained tactile representations through feature-wise linear modulation, improving success rate, completion time, and force stability on contact-rich insertion and drawer-opening tasks.

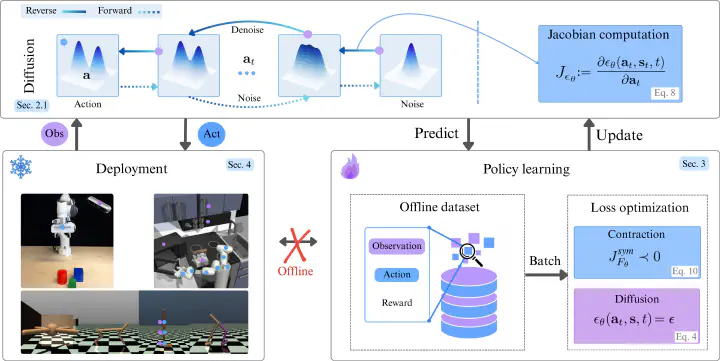
Methodology overview of Contractive Diffusion Policies: contraction loss during offline training and contractive ODE sampling at deployment.

ICLR 2026

Contractive Diffusion Policies: Robust Action Diffusion via Contractive Score-Based Sampling with Differential Equations

Amin Abyaneh, Charlotte Morissette, Mohamad H. Danesh, Anas Houssaini, David Meger, Gregory Dudek, Hsiu-Chin Lin

CDPs add a contraction regularizer to diffusion policies that pulls nearby sampling flows together, suppressing solver and score-matching errors and unwanted action variance. Backed by theory and a practical recipe with a single extra hyperparameter, they often outperform standard diffusion policies in simulation and on real robots, most clearly when data is scarce.

2025

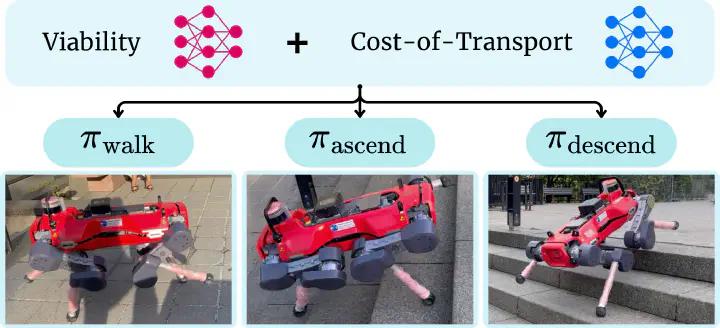
Overview of the VOCALoco framework showing skill viability prediction and selection.

IEEE RA-L 2025 · presented at ICRA 2026

VOCALoco: Viability-Optimized Cost-aware Adaptive Locomotion

Stanley Wu, Mohamad H. Danesh, Simon Li, Hanna Yurchyk, Amin Abyaneh, Anas El Houssaini, David Meger, Hsiu-Chin Lin

VOCALoco predicts the viability and cost of transport of several pretrained locomotion skills from local heightmaps, then executes the safest, most efficient one. It improves robustness on stair ascent and descent over an end-to-end DRL policy and transfers to a real ANYmal-D quadruped.